Project
Product design · healthcare impact
Prodigy: soft robotic rehabilitation
- SolidWorks
- SOFA
- Soft robotics
Kyphosis, an excessive forward curve of the upper spine, affects a large share of older adults, and the usual options are rigid braces, costly surgery, or constant clinic visits. Prodigy explores a softer path.
A soft exoskeleton that gently guides the spine
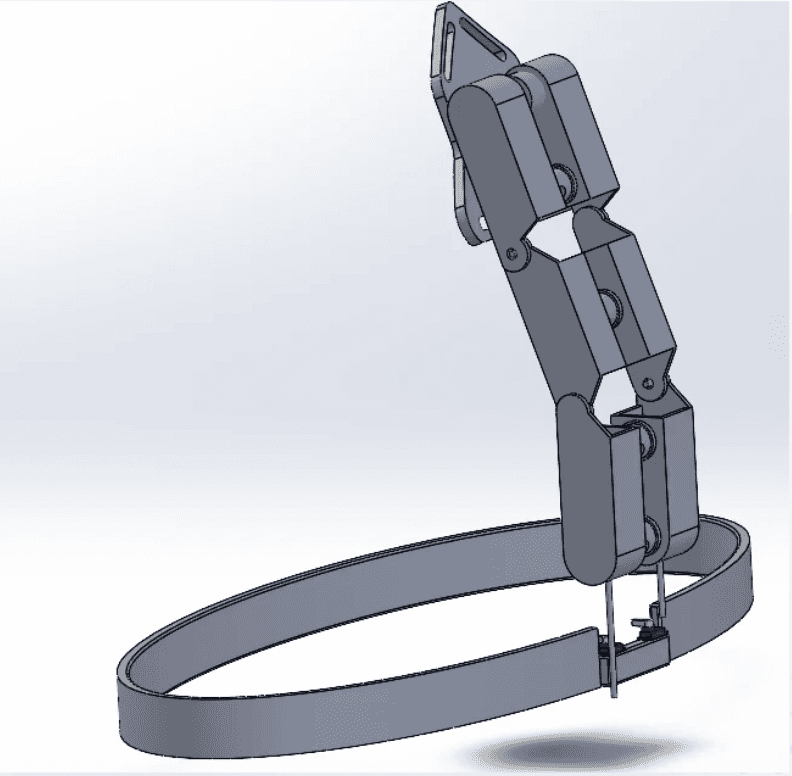
It’s a cable-driven wearable: a segmented dorsal actuator along the thoracic spine and a waist belt of servo motors that tension tendons to spread corrective force across the back rather than at one rigid point. The structure is designed to be 3D-printed in flexible TPU, so it can be made affordably, even at home.
Can posture care be soft, wearable, and cheap enough for home?
Proven in simulation before fabrication
I modeled the actuator geometry and cable routing in SolidWorks, then validated the mechanics in the SOFA framework with its SoftRobotics plugin, checking deformation, force-displacement, and comfort under realistic loading before building anything.
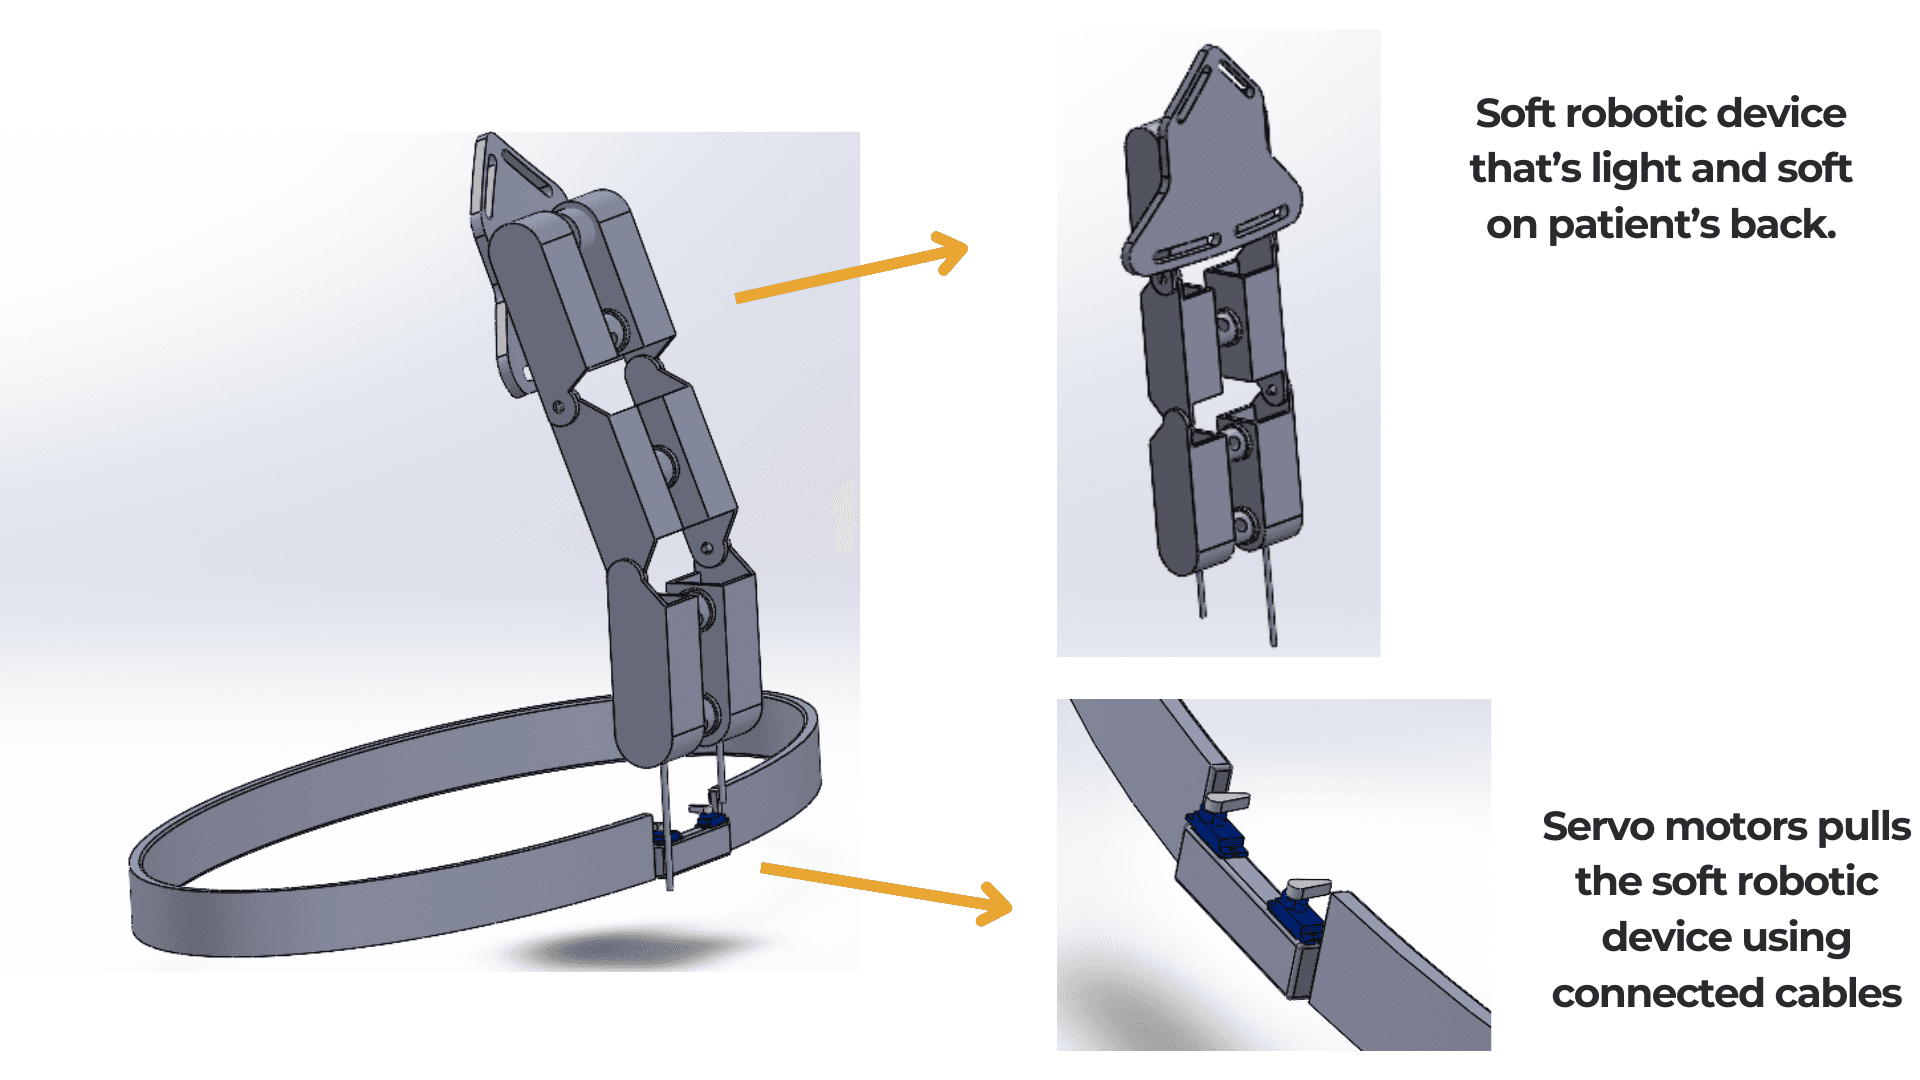
Actuator prototype
Prodigy began as a team hackathon project and placed Runner-Up at the KUEC Robothon at RoboCup UAE ($7,000 prize). We’re currently working on designing it in a more affordable and sustainable format.
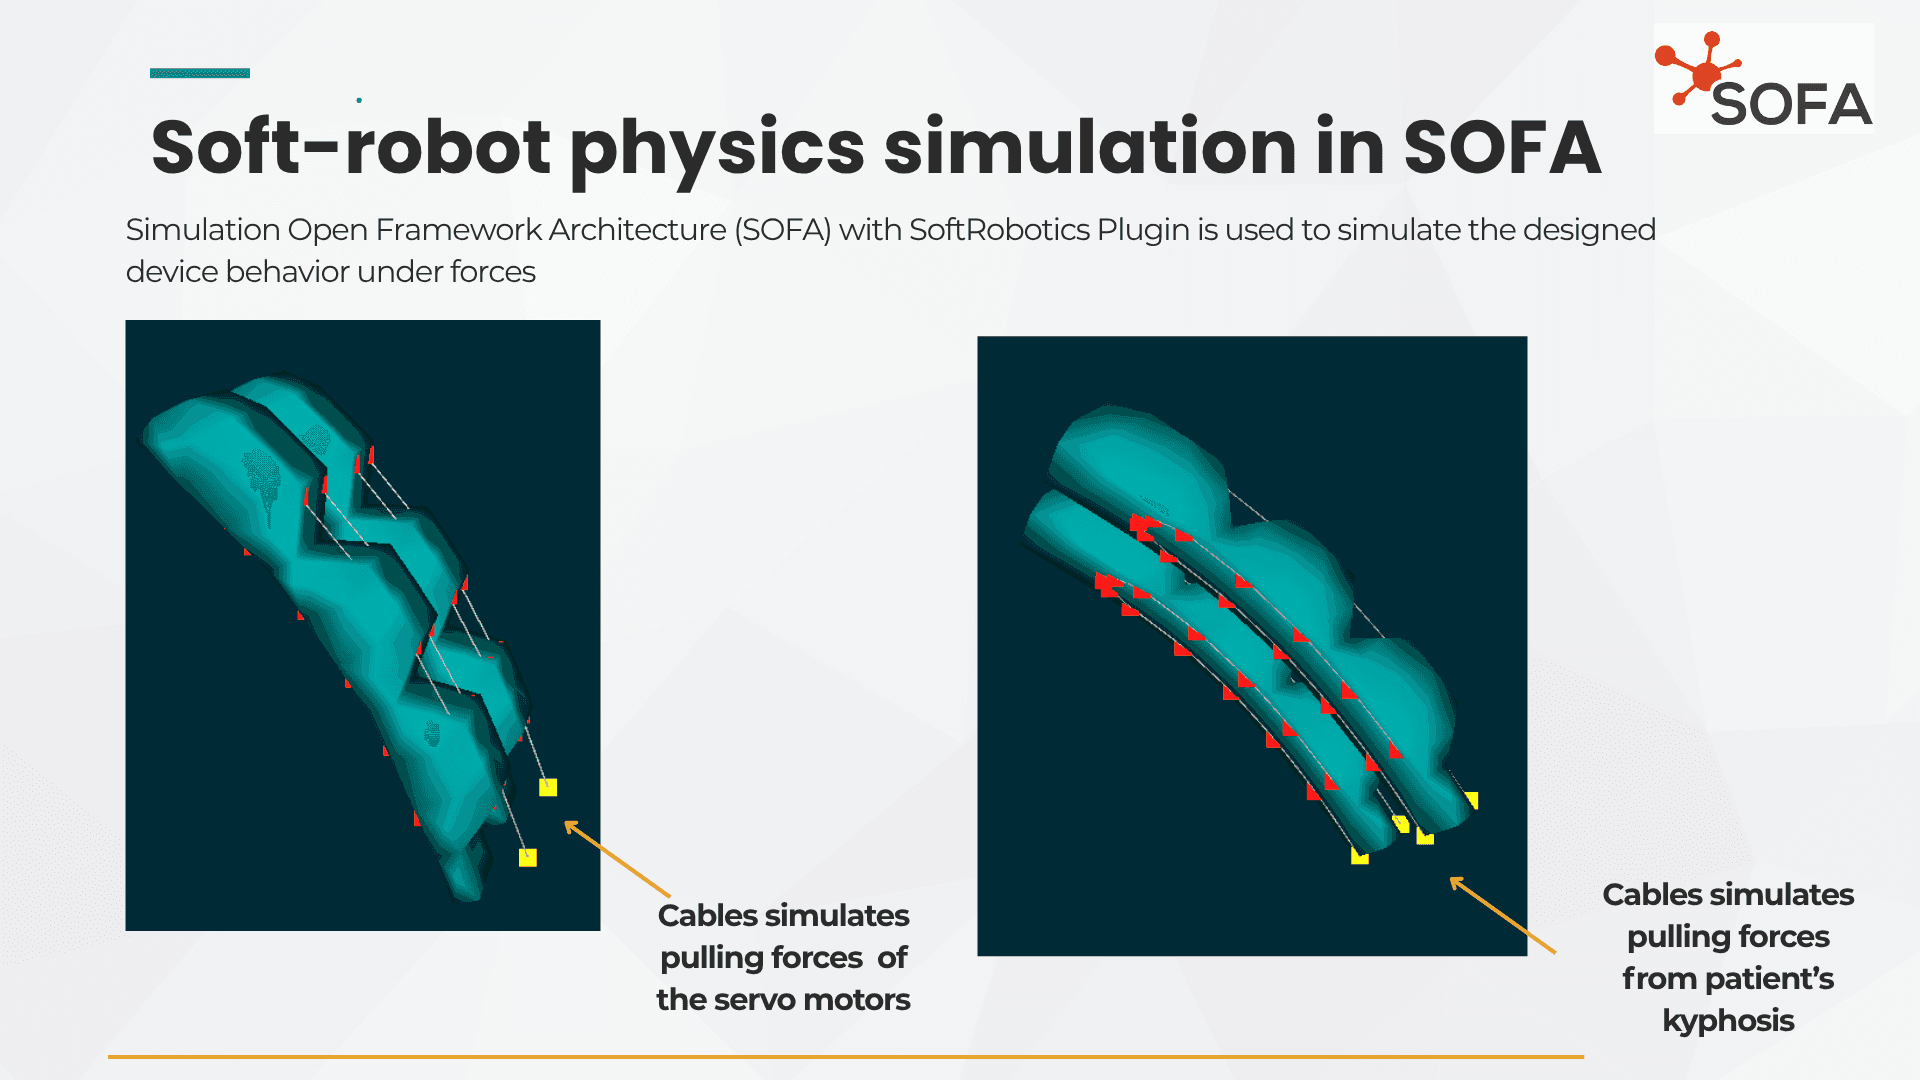
SOFA simulation