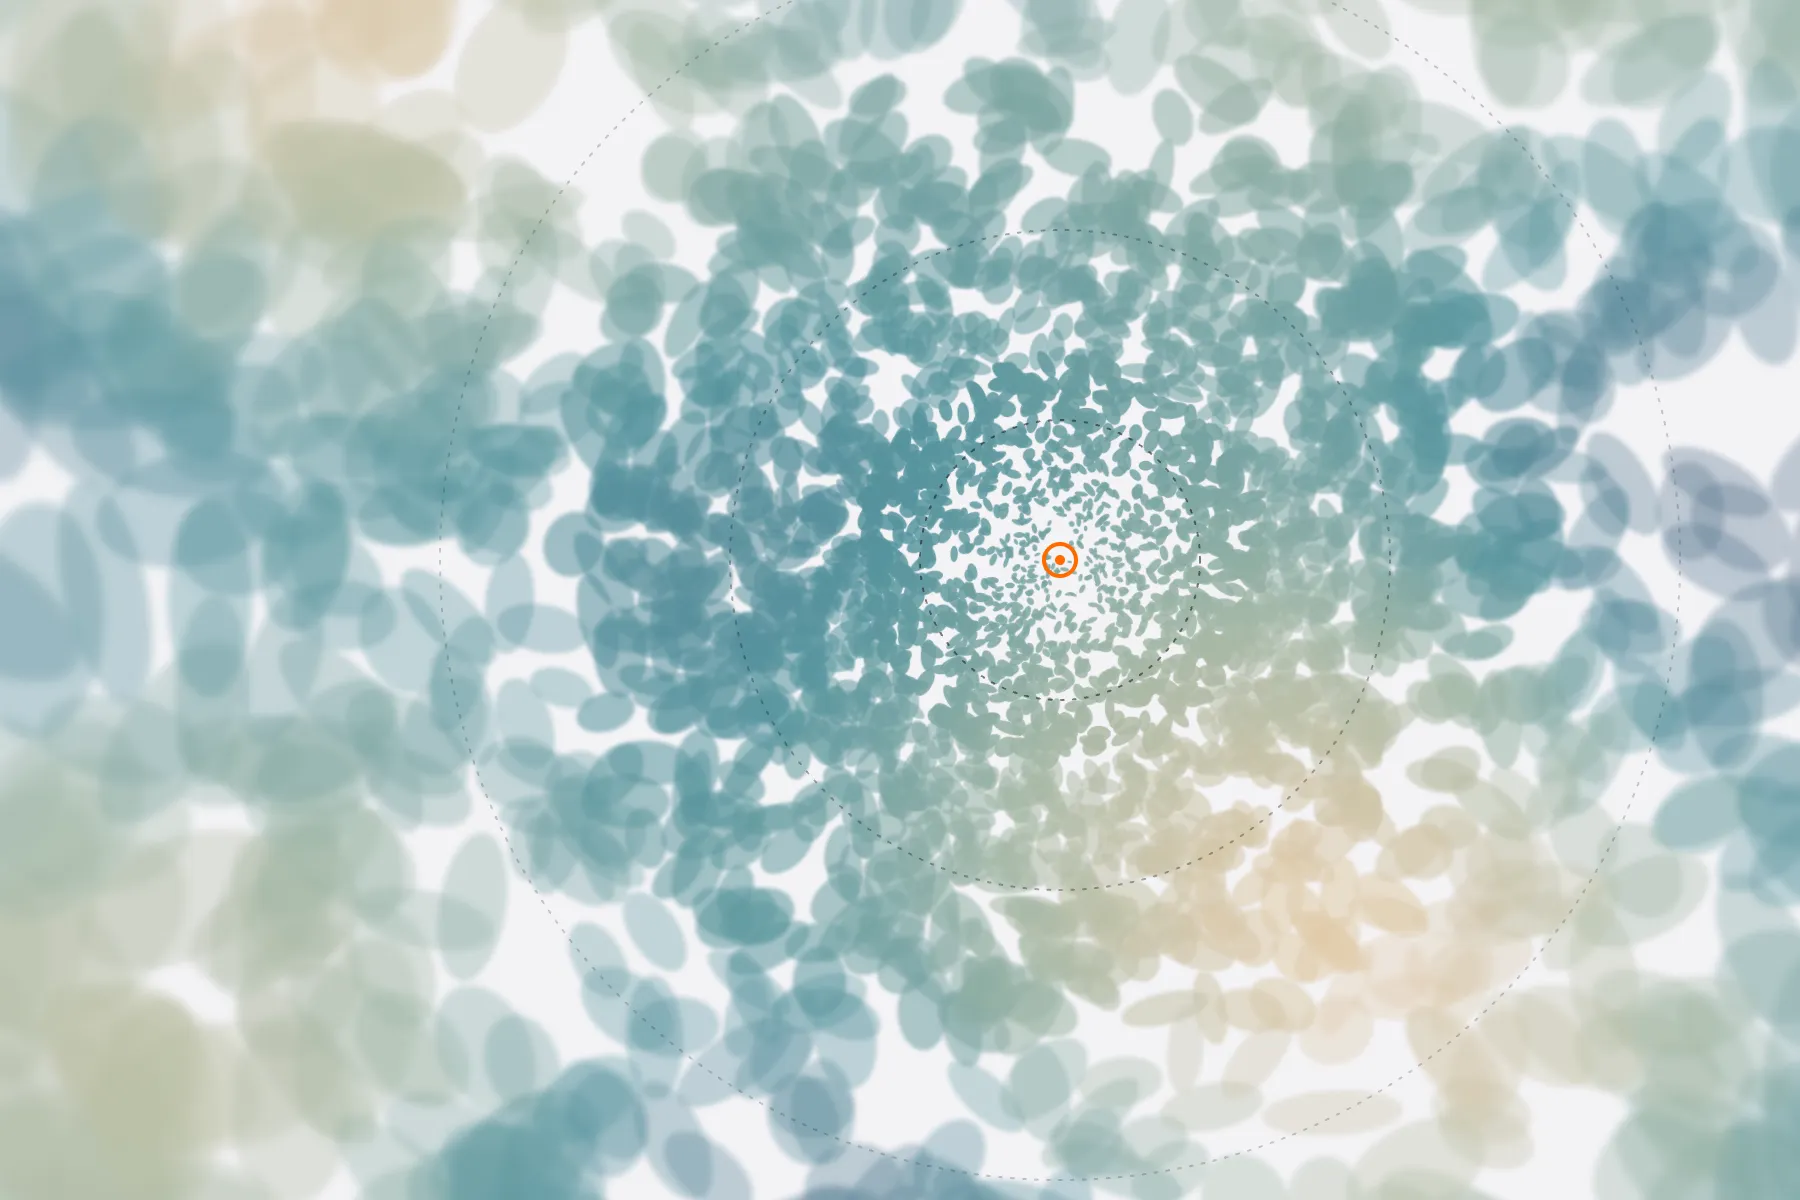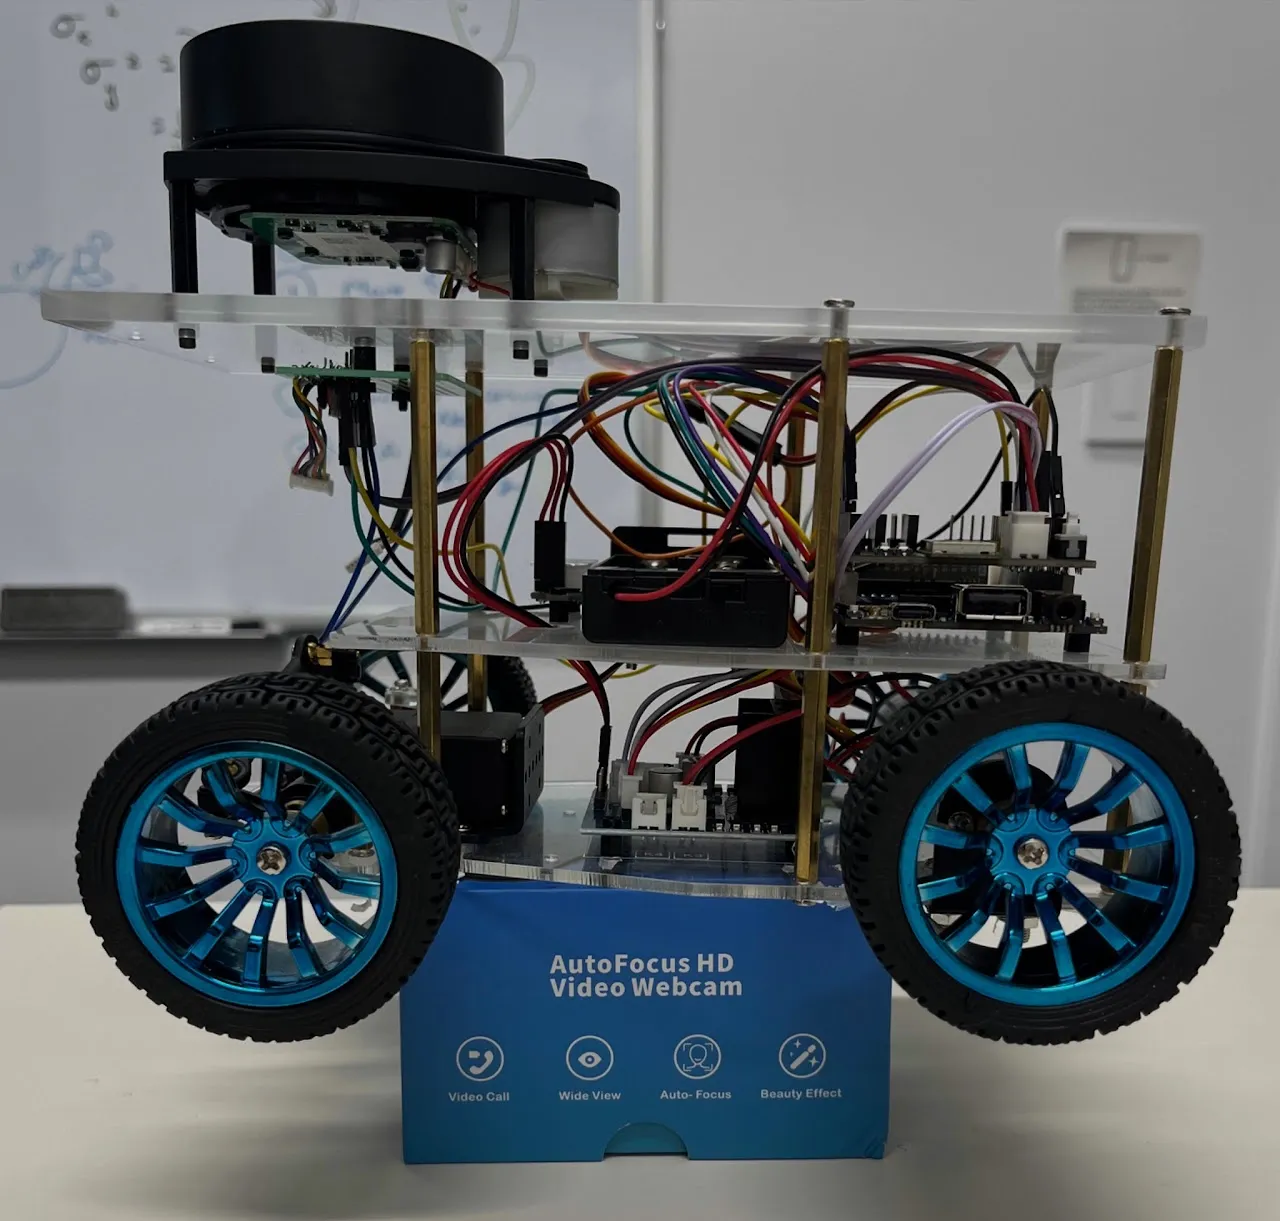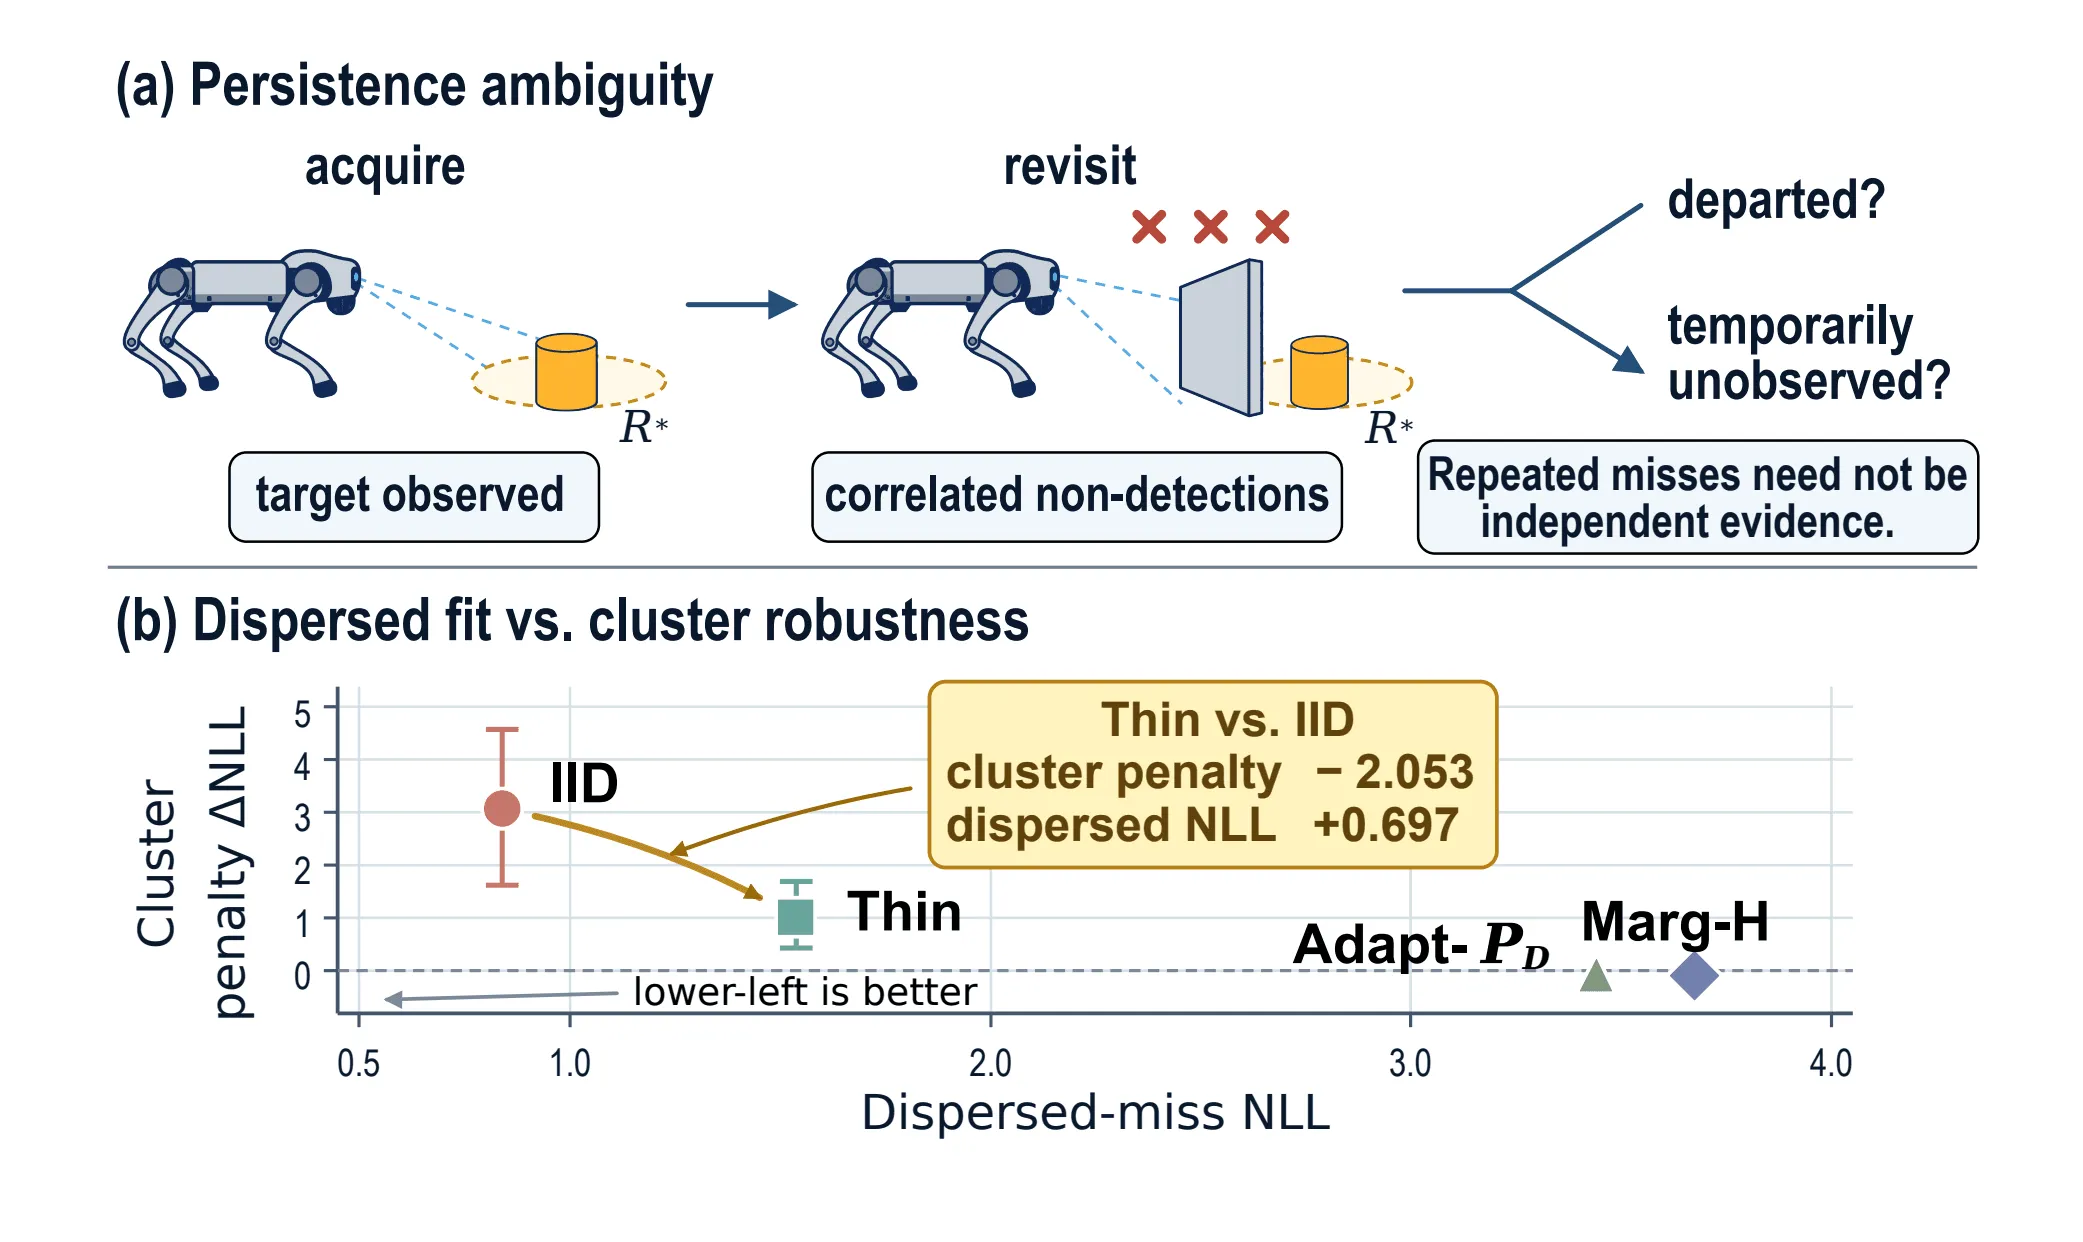
Object persistence under correlated RGB‑D misses
A robot's camera keeps missing an object. Is it gone, or just hidden? How persistence filters should count repeated misses.
Hi, I'm Ahbab Siddiquee.
Currently
Publications
Previously
About
I'm Ahbab, an electrical engineering student at NYU. I build hardware and software that let technology sense and respond to people, drawing on experience in wearables, robot perception, and VR. I'm working toward graduate study in HCI.
I grew up in Chittagong, Bangladesh, and take photos and make Blender renders when I'm not in the lab. You can see a few here.
Read the full story →